Case Study — 09 / Independent Robotics Engineer / 2024
Autonomous SumoBot
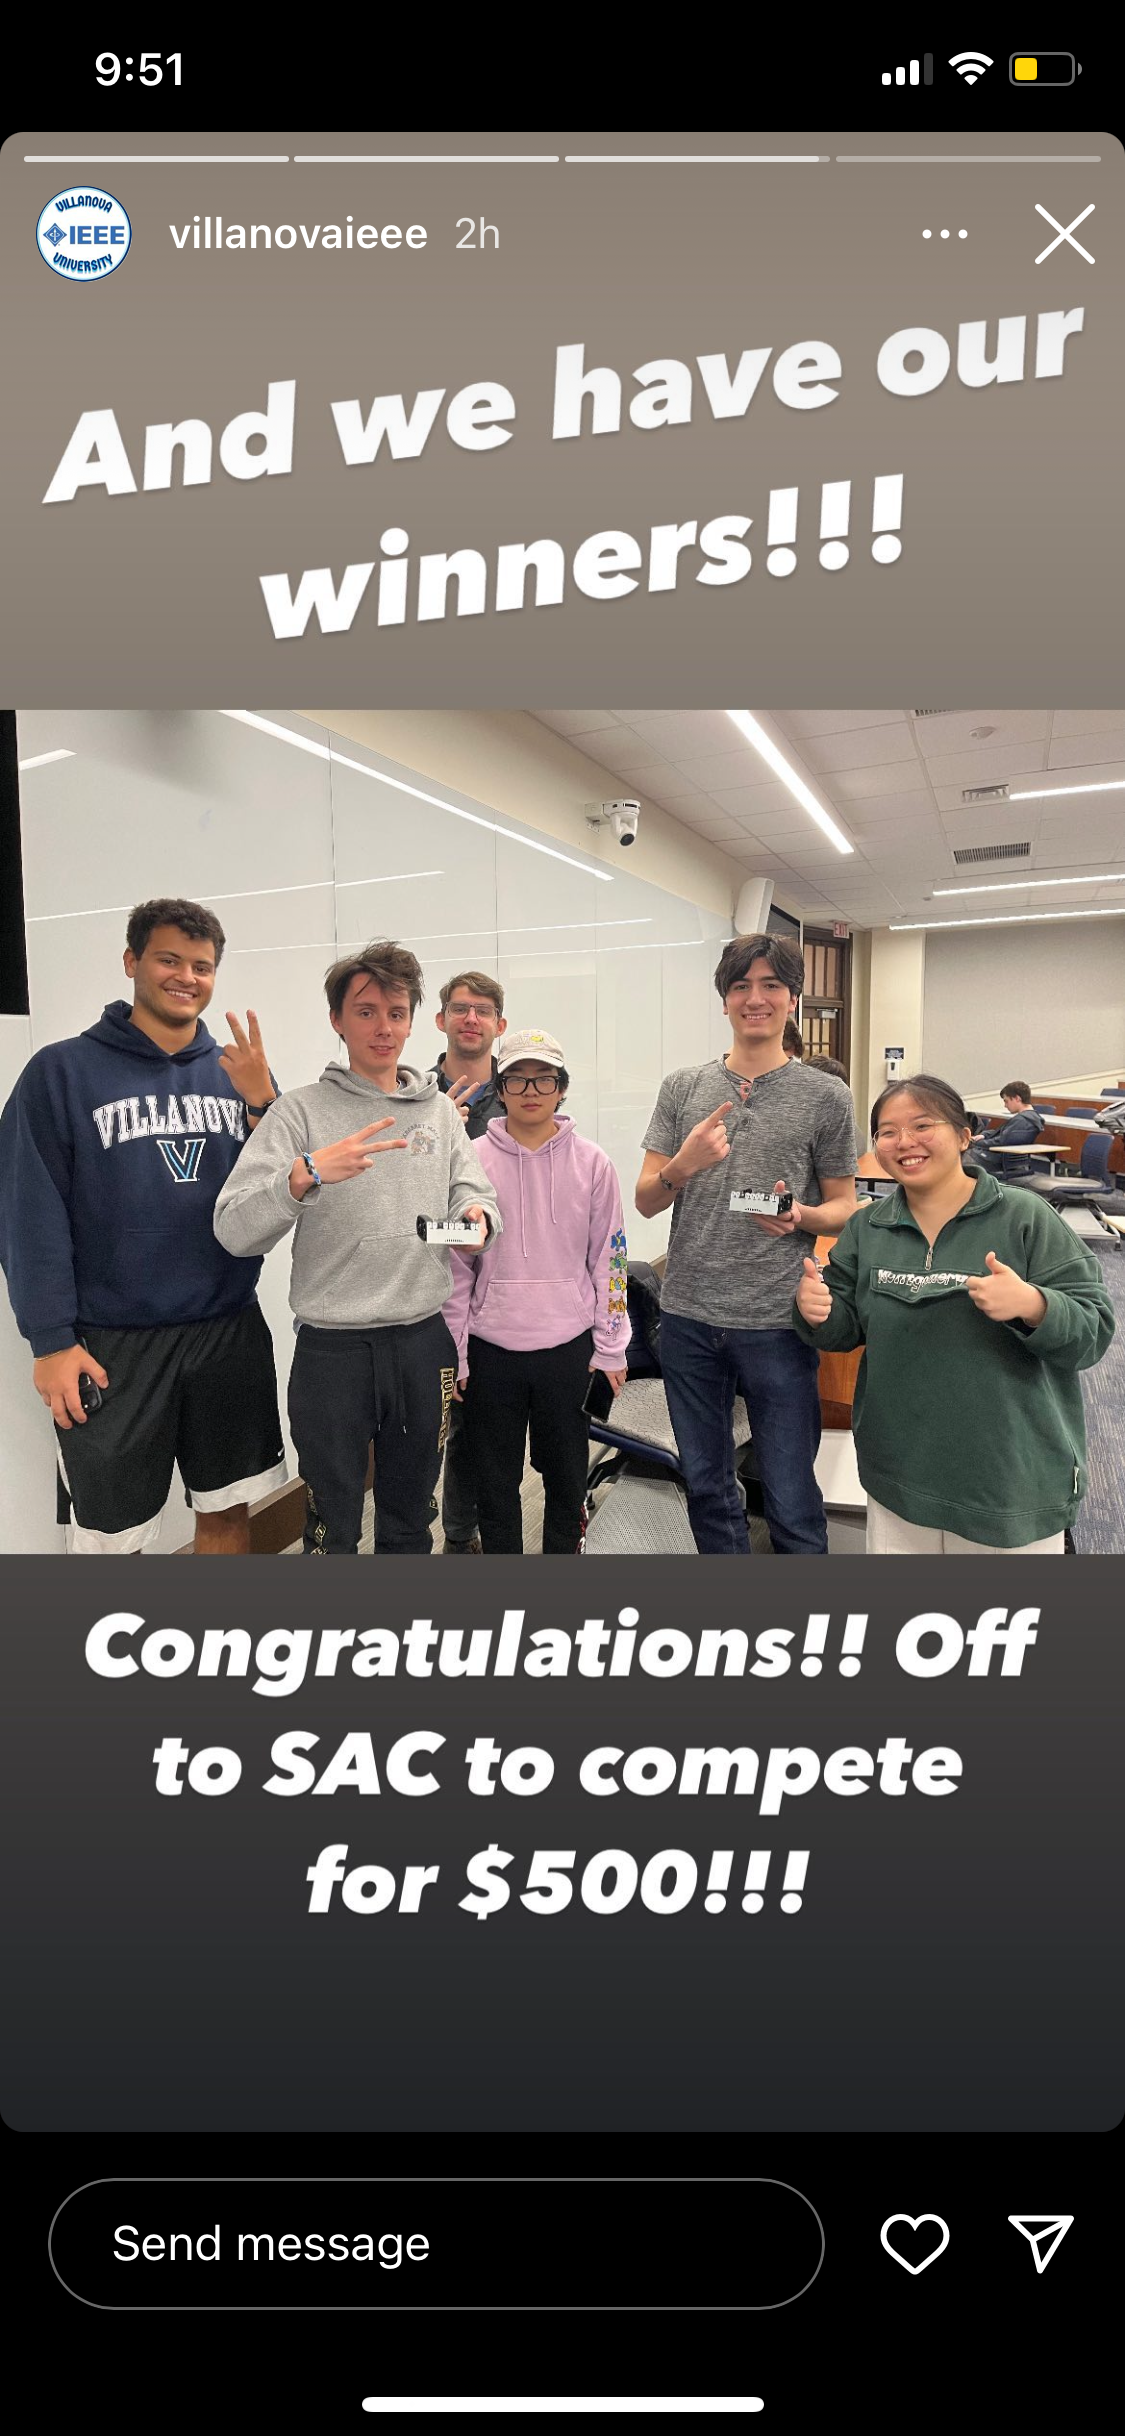
Engineered an autonomous combat robot featuring high-frequency sensor fusion and reactive state-machine control, securing 1st place at Villanova University.
A major embedded systems challenge was selecting between multiple autonomous algorithms (tactics) prior to a match without adding the weight and complexity of an LCD screen. I implemented a binary-multiplexed state selection system utilizing just 3 push-buttons. By reading the button states as a 3-bit binary integer during the startup sequence, I could select from 8 distinct algorithms and tactical behaviors using O(1) complexity, demonstrating resource-constrained hardware optimization.
I applied a similar binary logic structure to the robot's locomotion autonomy. Instead of writing slow, deeply nested conditional statements to handle edge-detection, the 5 downward-facing IR reflectance sensors were read as a 5-bit integer (providing 32 unique boundary states). This bitmask encoded the exact orientation and angle of the robot relative to the edge of the ring. A fast lookup table instantly triggered the corresponding high-G evasion maneuver based on that specific orientation, keeping the control loop latency strictly under 100ms.
Developed bare-metal C++ firmware on an ATmega32U4, implementing a high-frequency perception loop. Fused telemetry from a 6-axis IMU (accelerometer/gyroscope), multi-directional IR proximity arrays, and the bitmasked reflectance sensors. Integrated closed-loop PID motor control via quadrature encoders, optimizing torque vectoring for maximum traction during systematic search, rapid target engagement, and defensive repositioning.
Next Project — 06